Delay-Aware Shared Control for Teleoperation Systems: Intent Trajectory Prediction Under Communication Latency
Jinwei Liu, Pengfei Li, Yaqing Zhou, and 3 more authors
IEEE Internet of Things Journal, 2026
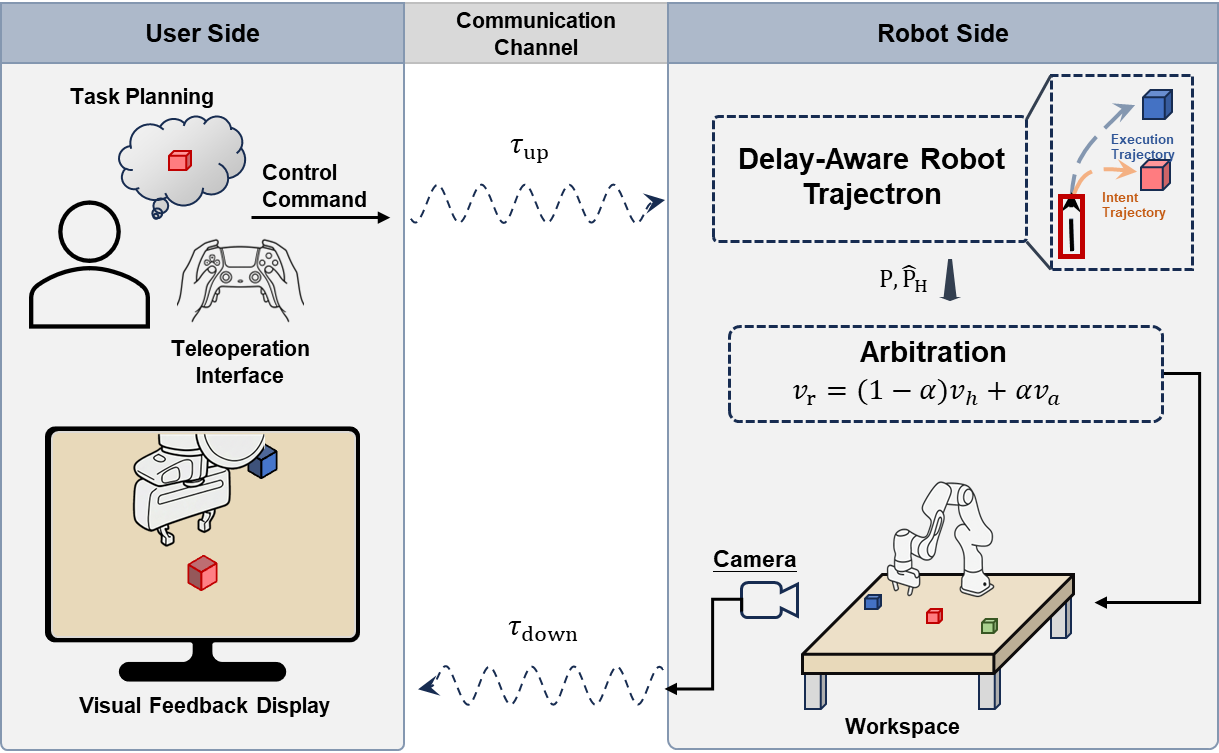
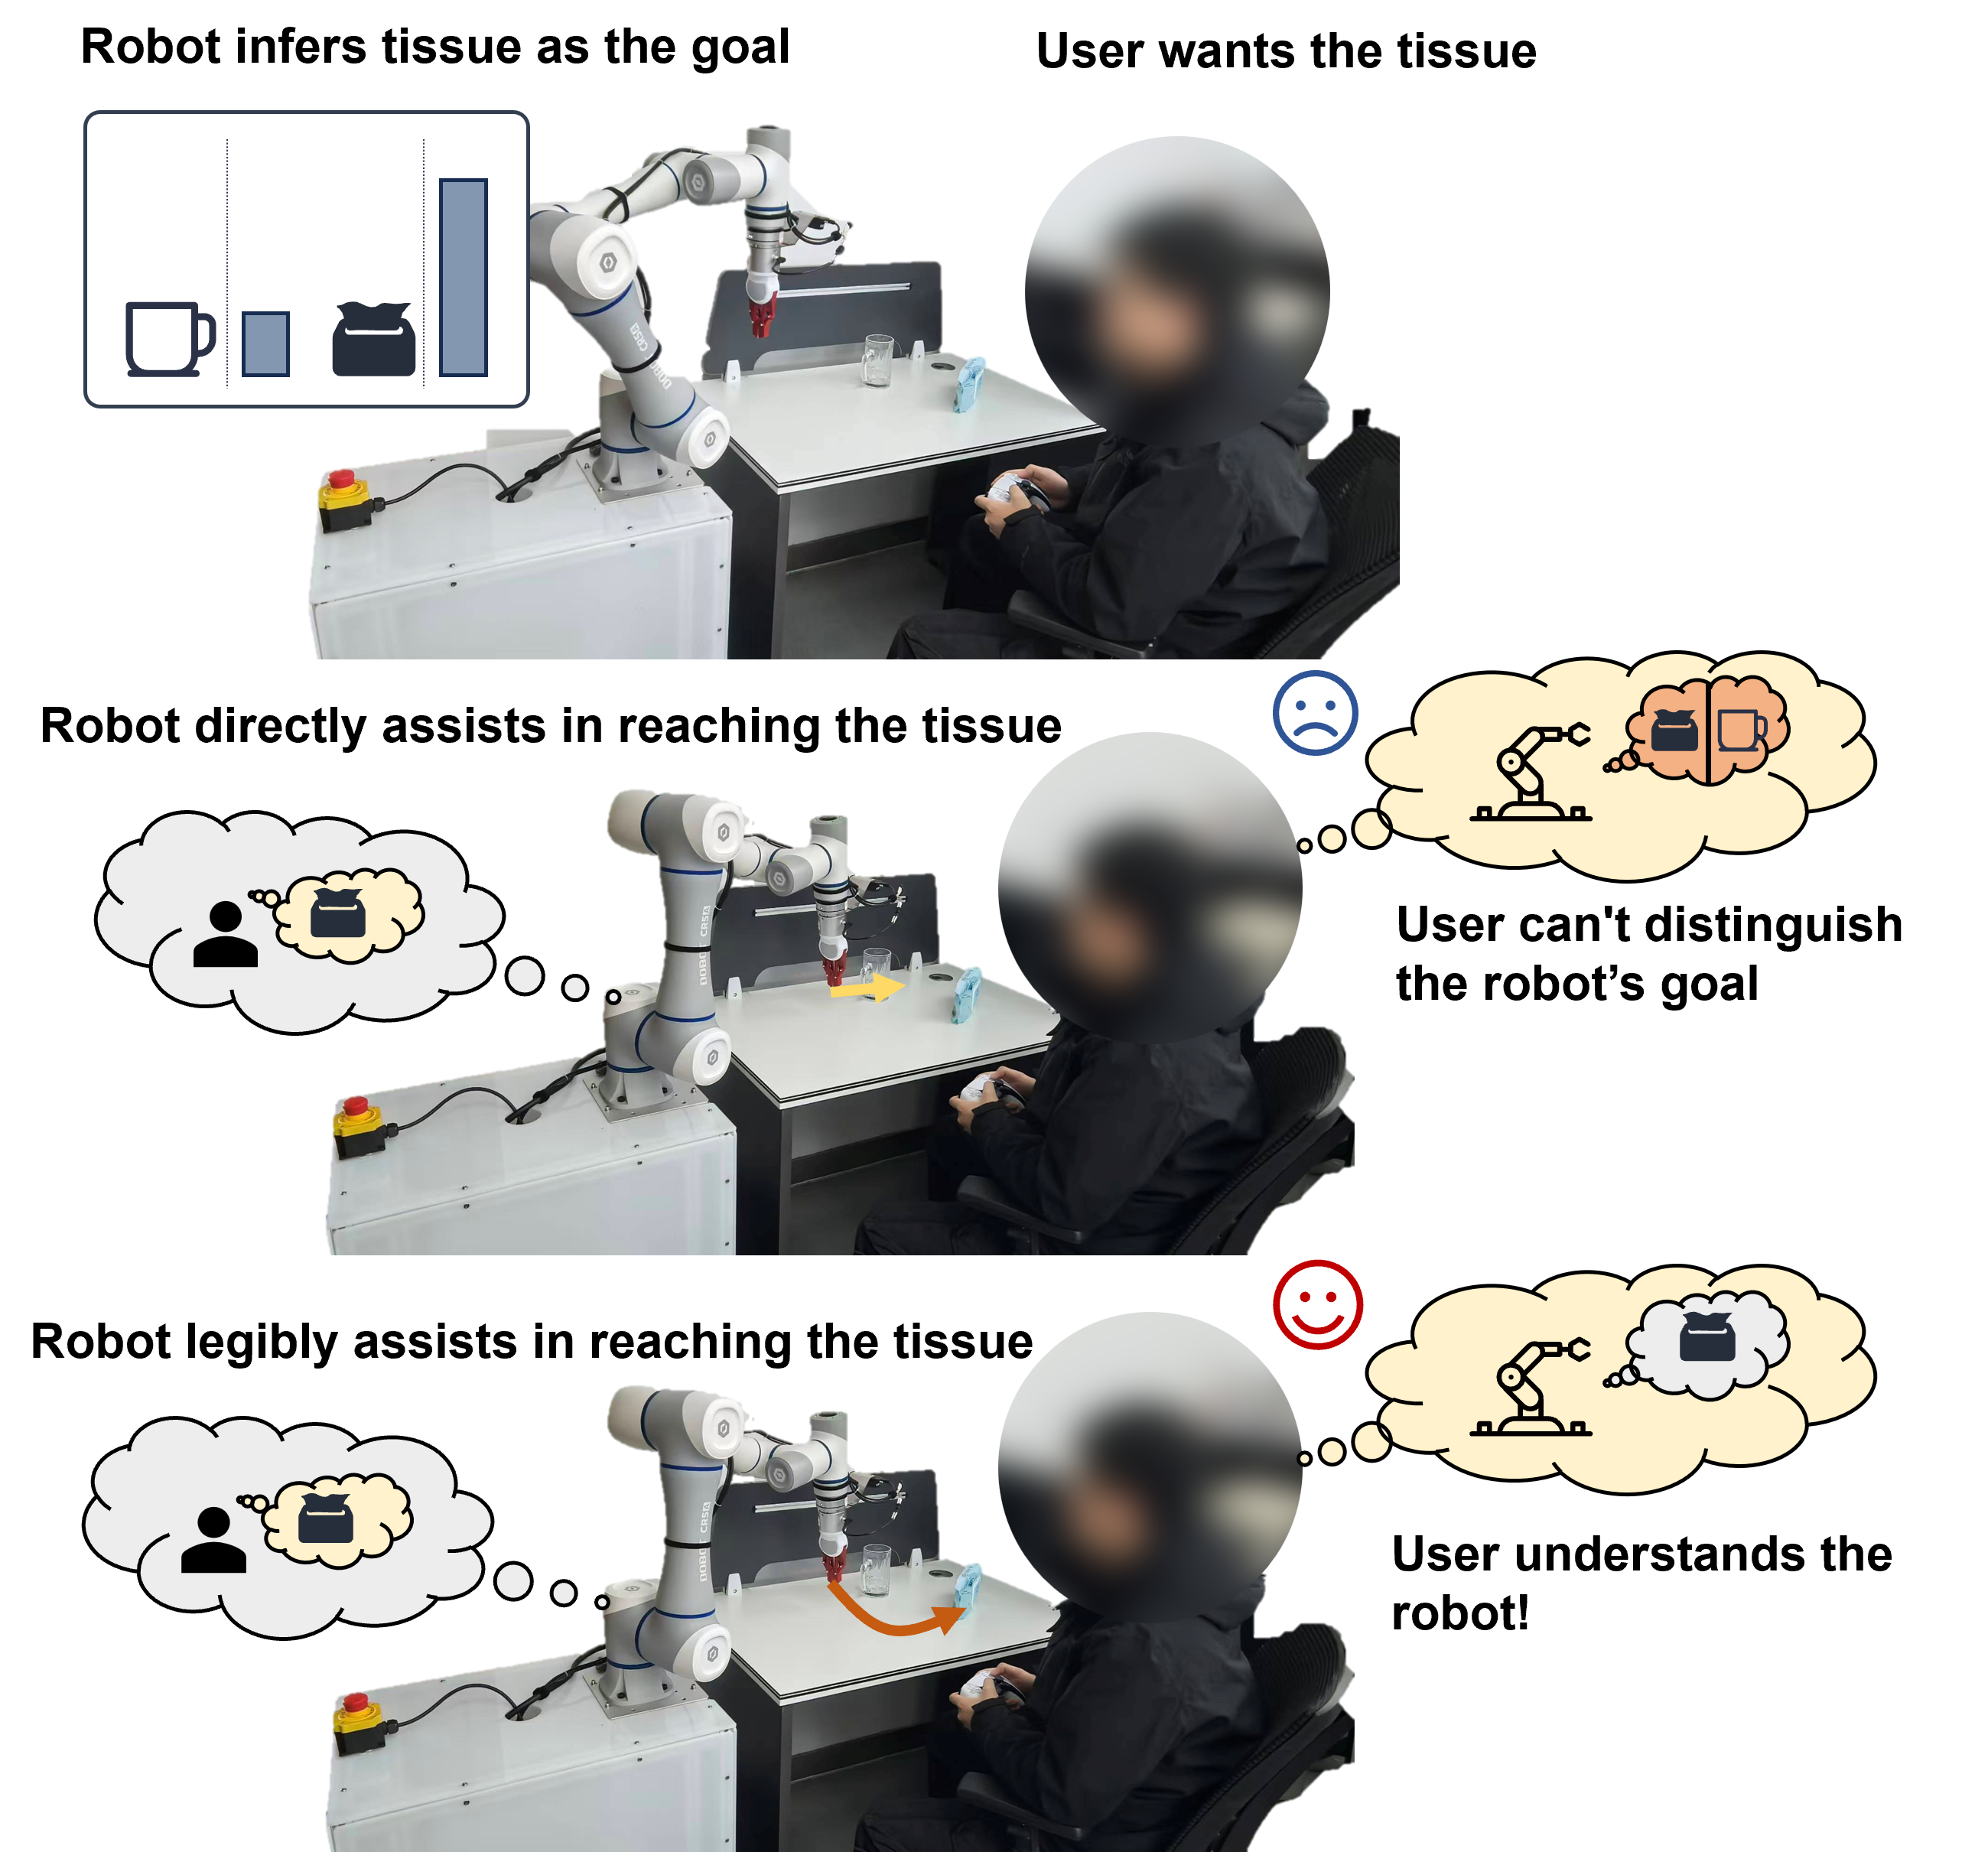
Shared-control teleoperation systems, which combine human cognitive versatility and robotic precision, are essential for executing complex tasks in inaccessible environments. A critical challenge in such systems is accurately estimating the operator’s intent to ensure the robot’s assistive actions align with the operator’s goals. Traditional trajectory prediction methods estimate the robot’s future path as the operator’s intent. However, without accounting for communication delays, these methods predict the robot’s execution trajectory, which diverges from the operator’s intended trajectory due to the delays. To address this issue, we propose the delay-aware Robot Trajectron (DA-RT), which restores the causal relationship between observed commands and actions by leveraging temporally aligned data and a delay-conditioned attention pooling mechanism. This enables DA-RT to accurately estimate the operator’s intended trajectory under communication delays. Then, we integrate DA-RT with an artificial potential field based controller and a dynamic arbitration mechanism to form a delay-aware shared-control framework, which adjusts the level of assistance based on delay magnitude and the agreement between the operator’s command and the robot’s motion. In human-in-the-loop experiments with fifteen participants, our approach demonstrated significant improvements in both task success rate and efficiency, outperforming traditional methods.
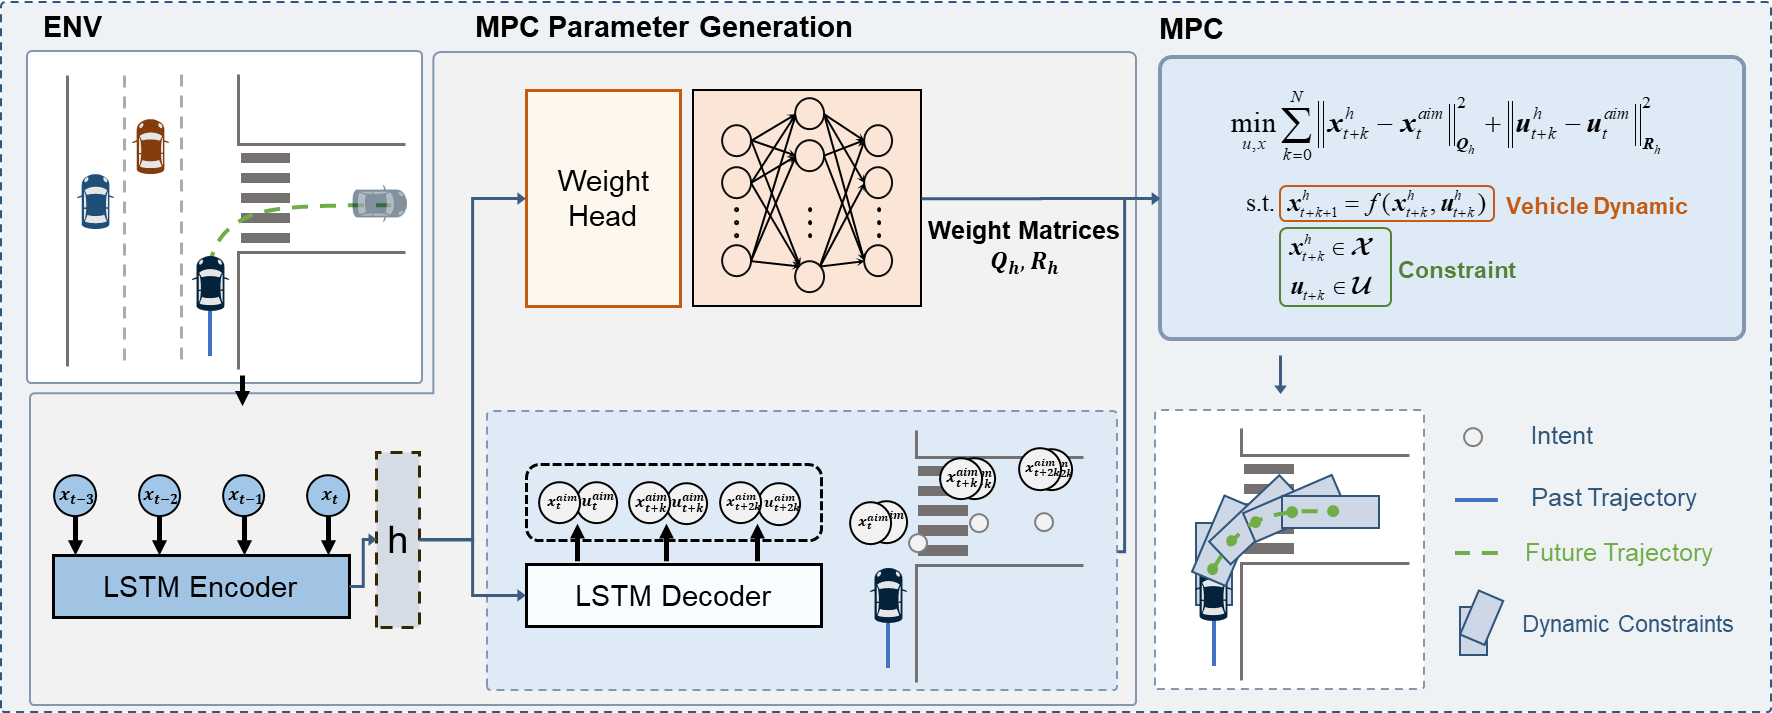 LSTM-MPC: Physically Feasible and Interpretable Trajectory PredictionIn International Conference on Guidance, Navigation and Control, 2026Accepted