Jinwei Liu

Jinwei Liu
Ph.D. Student in Control Science and Engineering
University of Science and Technology of China
Hi there! This is Jinwei Liu. You can call me Kenway. I am currently a Ph.D. student in Control Science and Engineering at the University of Science and Technology of China through a master’s-to-Ph.D. transfer, advised by Prof. Yun-Bo Zhao in the Networked Intelligent Control Lab (NICLab).
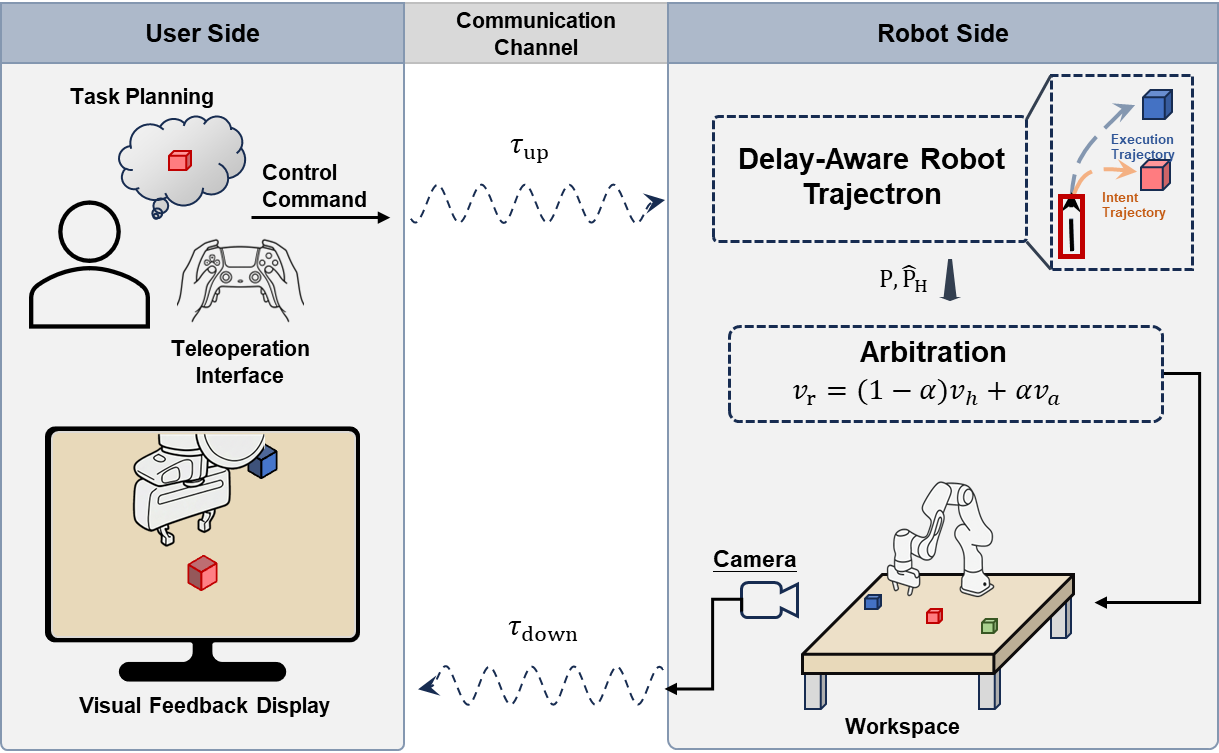
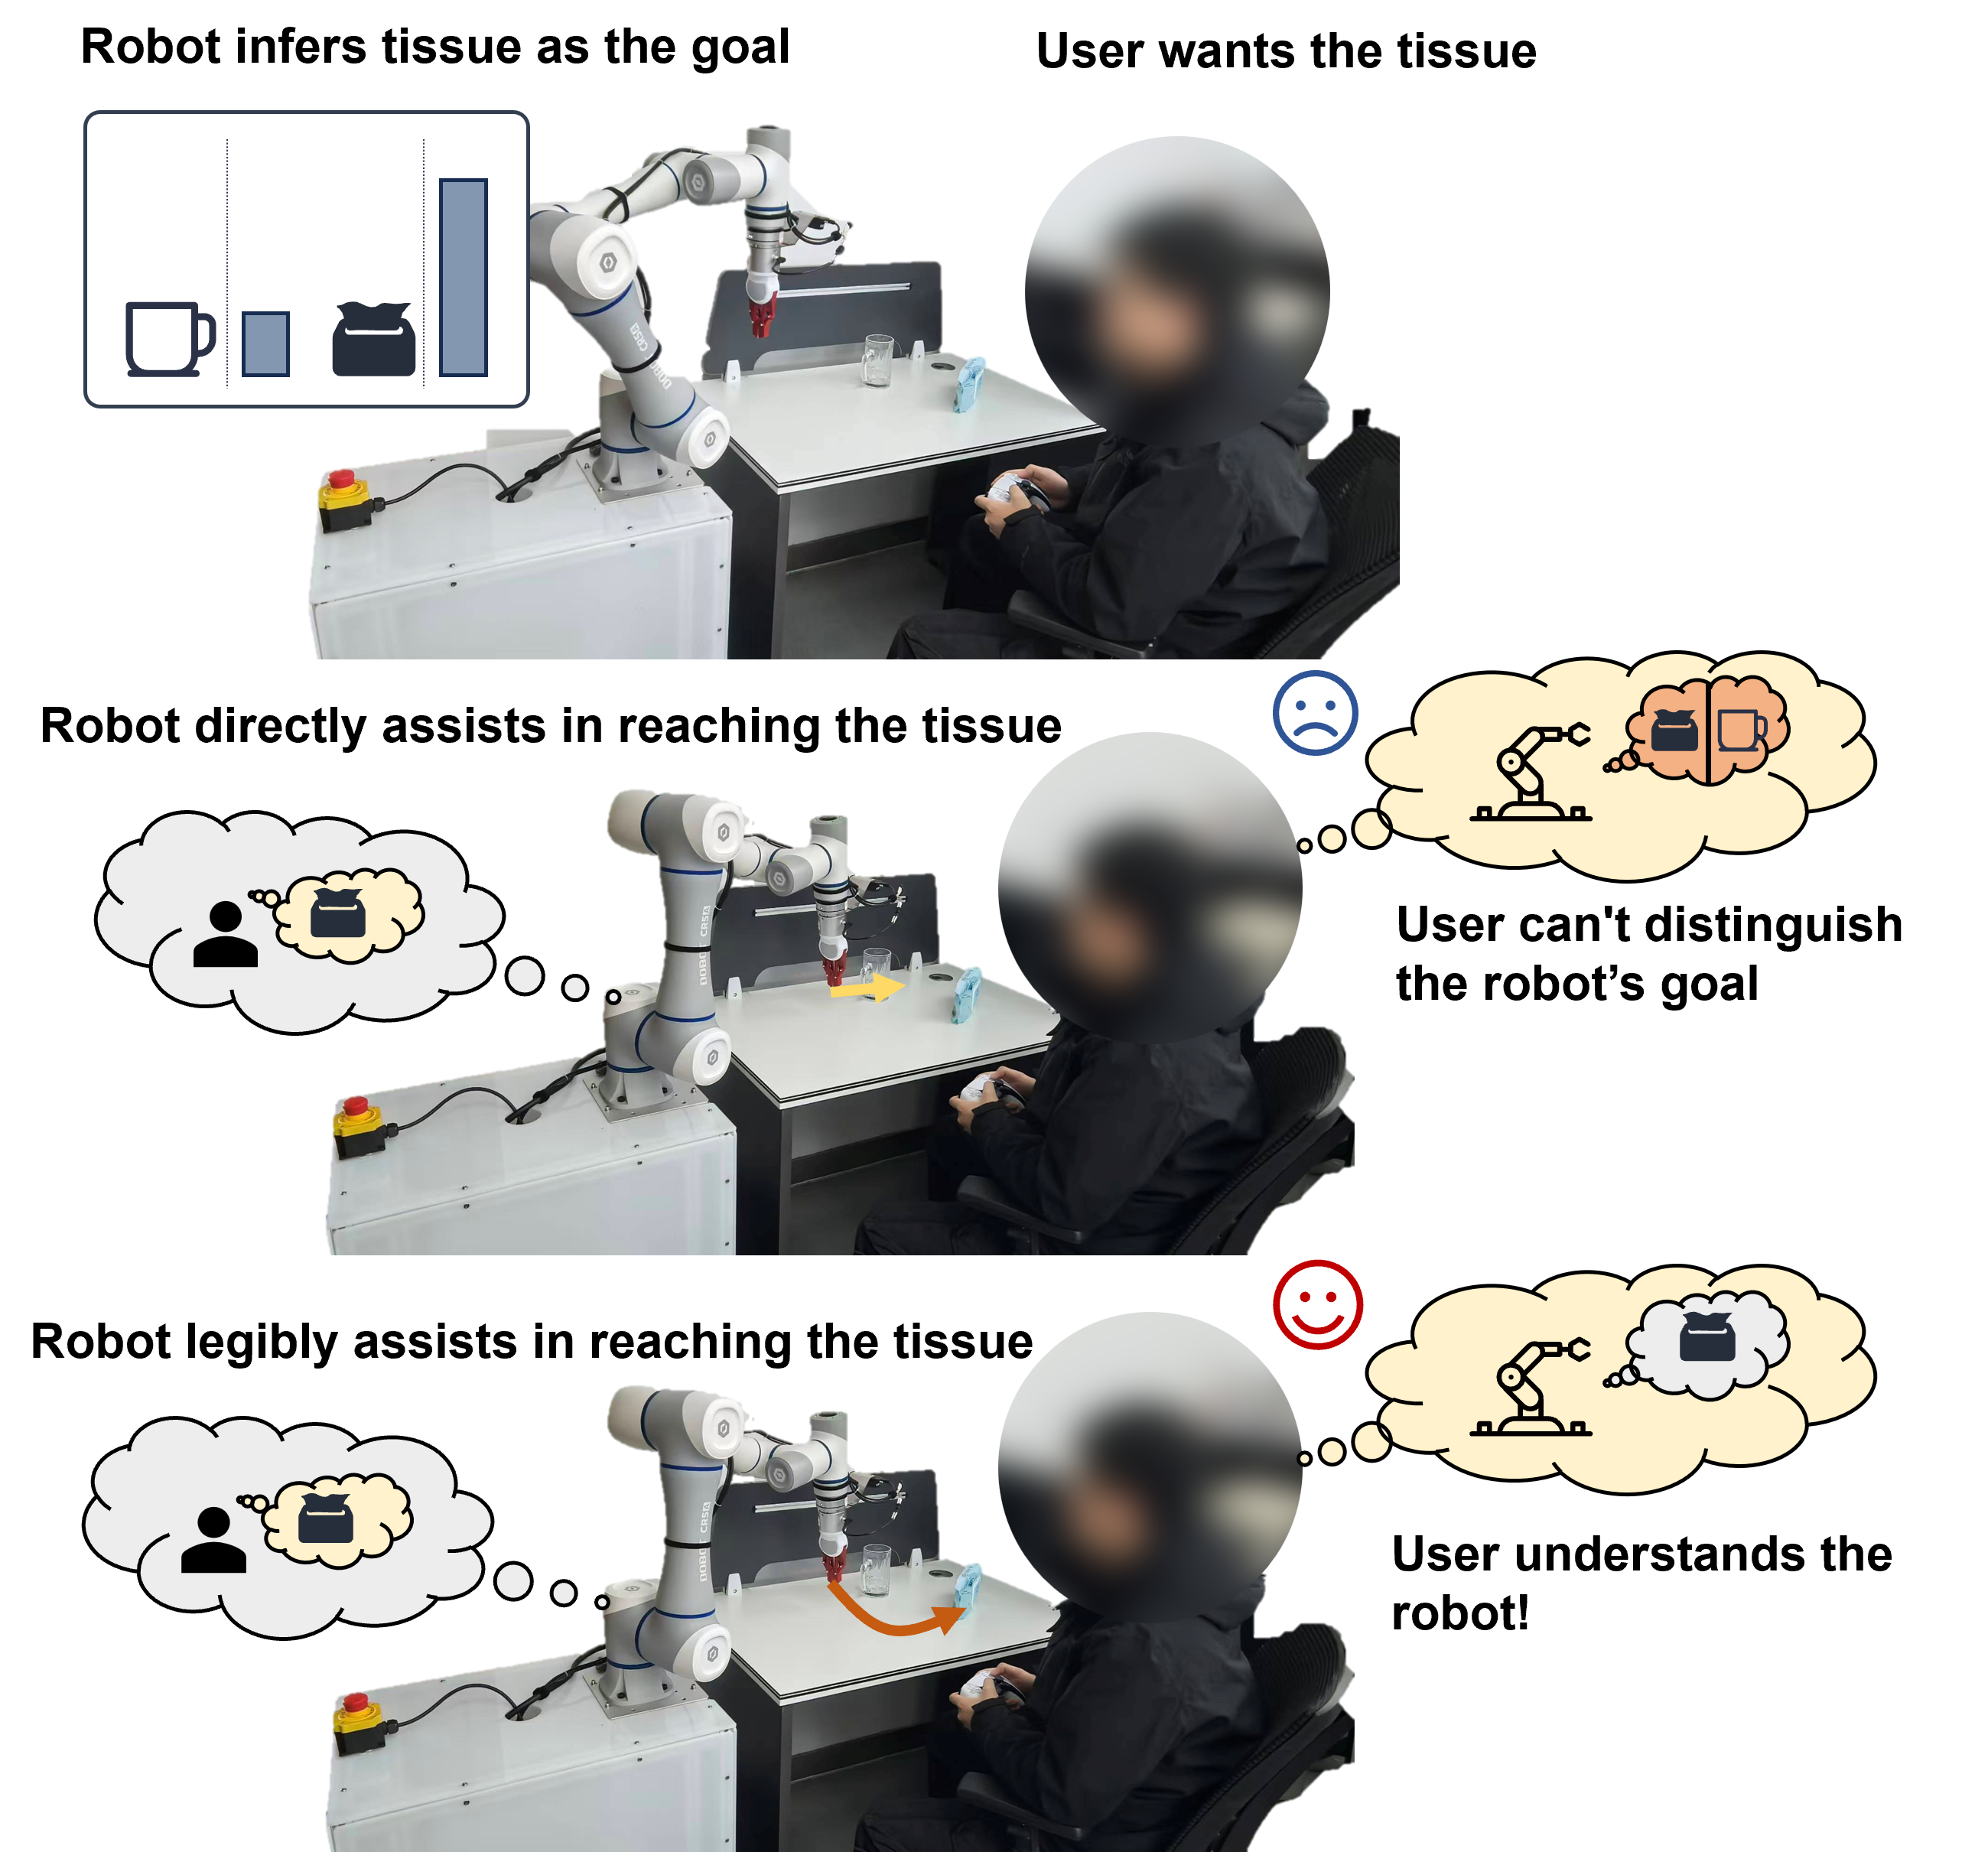
My research focuses on hybrid intelligence and shared autonomy in human interaction with machines, robots, and AI systems, with an emphasis on real-time intent inference, legible robot behavior, adaptive assistance, and safe, natural collaboration. During my master’s study, I worked with Pengfei Li, Associate Researcher at USTC.
Research Interests
Human-Augmented Machines
Human guidance improves how embodied and intelligent systems learn, adapt, and intervene under uncertainty.
Human-in-the-loop imitation learning and human-in-the-loop reinforcement learning.
Learning-based control, uncertainty-aware intervention, reinforcement learning, and MPC.
Machine-Assisted Humans
Intelligent systems assist people by understanding human intent and communicating their own assistance behavior.
User modeling, intent inference, trajectory prediction, and shared autonomy.
Robot motion legibility, implicit communication, belief expression, and agency-preserving assistance.
Activities
Dobot, Shanghai, China.
Busan, South Korea.
News
| 2026.10 |  I have been selected for USTC’s 2026 Doctoral Training Program for Urgently Needed Fields. |
|---|---|
| 2026.09 | Our interdisciplinary project on sense of agency in human–assistive robot interaction, co-led by Jinwei Liu and Han Shi, has received RMB 100,000 in funding from USTC’s 2026 “璧合” program. |
| 2026.06 | Our paper Legible Shared Autonomy: Implicit Communication of Robot Belief Through Motion has been accepted to IROS 2026. |
Selected Publications
Education
University of Science and Technology of China
- Ph.D. in Control Science and Engineering,
2026.06 - Present - Master’s-to-Ph.D. transfer; combined master’s-doctoral track
University of Science and Technology of China
- M.Eng. in Artificial Intelligence,
2024.09 - 2026.06 - Weighted average:
91.09 - GPA:
3.99/4.3 - National Scholarship
Ocean University of China
- B.Eng. in Automation,
2020.09 - 2024.06 - Rank:
1/89 - Weighted average:
92.42 - GPA:
3.82/4.0 - National Scholarship (twice)
- Honorary Bachelor’s Degree of Ocean University of China